-
Prosthetics and Rehabilitation
-
01
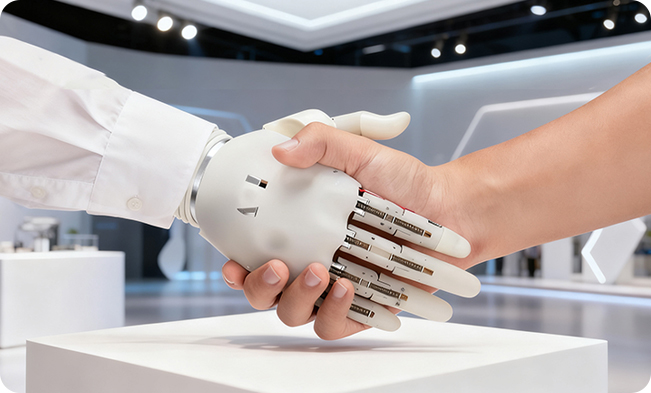
Myoelectric Prosthetic Hand
Uses muscle signals from the residual limb to control hand movements within milliseconds. Tactile feedback and adaptive grip control support more natural, independent use.
-
02
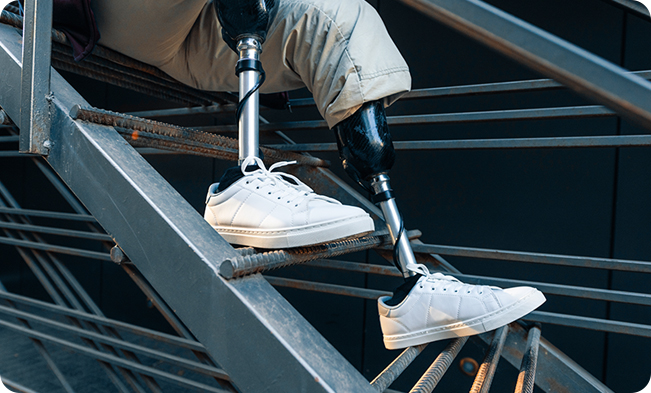
Intelligent Prosthetic Knee
Uses muscle signals and gait sensors to detect movement intent and adjust hydraulic resistance. It is designed to support stable walking in different conditions.
-
03
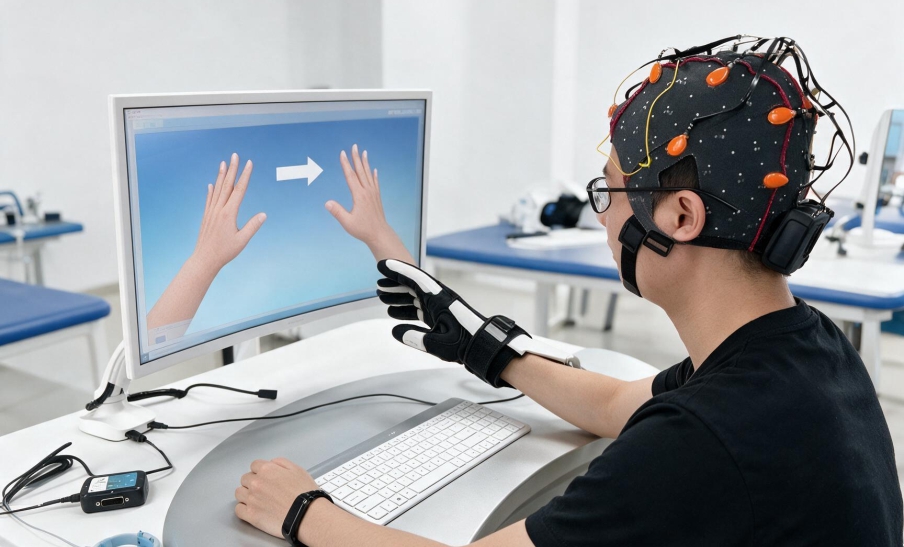
Rehabilitation System with a Myoelectric Control Interface
Combines biosignal sensing and interactive training software to create personalized rehabilitation plans for postoperative recovery and residual-limb muscle training. It can also be used with a prosthesis during rehabilitation.
-
-
Components for Industrial and Service Robots
-
01
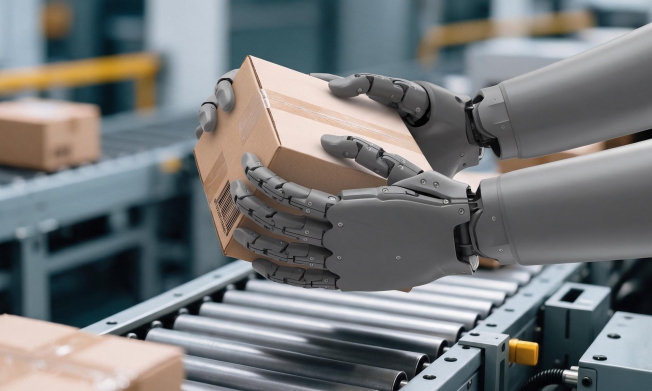
Universal Dexterous Robotic Hand
A robotic hand for precise sorting, delicate assembly and service-robot tasks. Force and touch sensors allow it to adjust grip automatically and handle objects more safely.
-
02
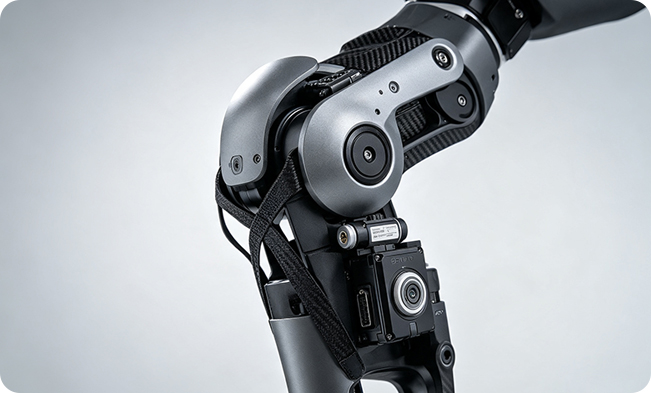
Bionic Servo Knee Module
A robotic knee module with inertial motion sensing and adaptive resistance control. It supports walking, slopes, squatting and load-bearing tasks in humanoid robots.
-
03
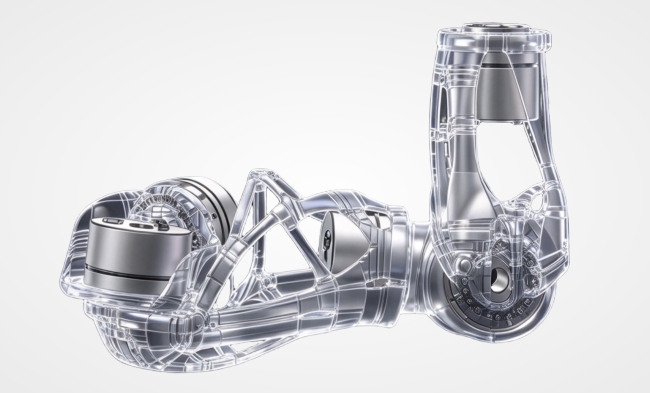
Bionic Elbow Module
A robotic elbow module with adaptive force control, multiple degrees of freedom and torque-and-position feedback. It supports wide-angle bending, impact protection and load-bearing tasks for collaborative and service robots.
-
Kapitels(Beijing) Technology Co., Ltd
Address:Room 413, 4th Floor, New Material Innovation Building, No. 7 Fenghui Middle Road, Haidian District, Beijing
Phone:400 999 6027
Website:http://www.kapitels.com
Email:sales@kapitels.com